Motivation
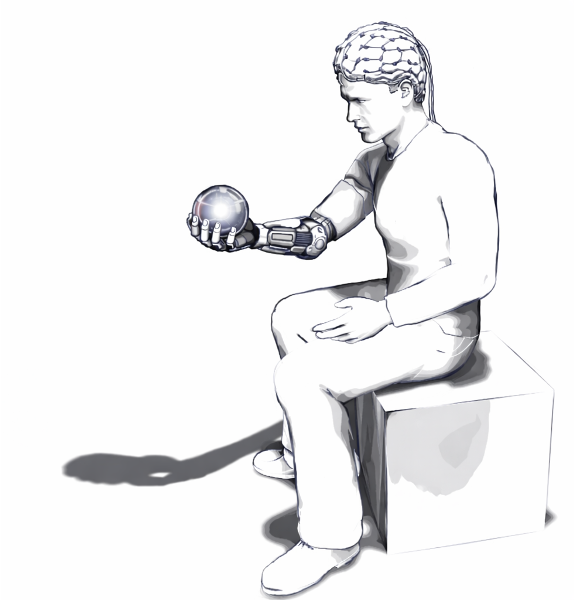
Current prosthetic devices are limited to simple grasp actions with uncontrolled compliance, and brain-machine interfaces focus mainly on motion. By extending our physics-grounded AI framework beyond robots and into bionics, we can generate physical interaction capabilities for prosthetic devices.
Vision and Impact
We want to enable amputees to train their own prosthetic limb to restore or extend their own physical interaction capabilities, and control it via brain signals. Our goal is to provide an open-source platform so that all people can use it, irrespective of their socio-economic condition or geographic location.
All research